Publications
Papers & preprints
Google Scholar →2026
-
SIGGRAPH
MeshFEM: A Block-accelerated Solver for Nonlinear Finite Elements
ACM Transactions on Graphics (SIGGRAPH 2026)Open access
@article{mohammadian2026meshfem, author = {Mohammadian, Haleh and Hu, Xinzhuo and Poranne, Roi and Panetta, Julian}, title = {MeshFEM: A Block-accelerated Solver for Nonlinear Finite Elements}, journal = {ACM Transactions on Graphics}, volume = {45}, number = {4}, articleno = {121}, year = {2026}, doi = {10.1145/3811386} } -
SIGGRAPH
Stress-Aware Panelization of Freeform Surfaces
ACM Transactions on Graphics (SIGGRAPH 2026)Open access
@article{hu2026stress,
 author = {Hu, Xinzhuo and Poranne, Roi and Panetta, Julian},
 title = {Stress-Aware Panelization of Freeform Surfaces},
 journal = {ACM Transactions on Graphics},
 volume = {45},
 number = {4},
 articleno = {87},
 year = {2026},
 doi = {10.1145/3811387}
}
2025
-
SIGGRAPH Asia
Computational Modeling and Design of Capacitive Stretch Sensors
ACM Transactions on Graphics (SIGGRAPH Asia 2025)
@article{gjoka2025capacitive,
 author = {Gjoka, Arvi and Sun, Yongkang and Poranne, Roi and Panozzo, Daniele},
 title = {Computational Modeling and Design of Capacitive Stretch Sensors},
 journal = {ACM Transactions on Graphics},
 volume = {44},
 number = {6},
 articleno = {240},
 year = {2025},
 doi = {10.1145/3763274}
}
2024
-
SIGGRAPH
Modal Folding: Discovering Smooth Folding Patterns for Sheet Materials using Strain-Space Modes
ACM SIGGRAPH 2024 Conference Papers
@inproceedings{tang2024modal, author = {Tang, Pengbin and Hinchet, Ronan and Poranne, Roi and Thomaszewski, Bernhard and Coros, Stelian}, booktitle = {ACM SIGGRAPH 2024 Conference Papers}, pages = {1--9}, title = {Modal Folding: Discovering Smooth Folding Patterns for Sheet Materials using Strain-Space Modes}, year = {2024} } -
arXiv
A Practical, Fast Method for Solving Sum-of-Squares Problems for Very Large Polynomials
arXiv preprint, 2024
@article{keren2024practical, author = {Keren, Daniel and Osadchy, Margarita and Poranne, Roi}, journal = {arXiv preprint arXiv:2410.19844}, title = {A practical, fast method for solving sum-of-squares problems for very large polynomials}, year = {2024} } -
Manuscript
Maximal Safety Regions for 2D Robotic Arms as Low Degree Sum-of-Squares Programming
Manuscript, 2024
@article{kerenmaximal, author = {Keren, Daniel and Shahar, Amit and Poranne, Roi}, title = {Maximal Safety Regions for 2D Robotic Arms as Low Degree Sum-Of-Squares Programming} } -
ICRA
Efficient Polynomial Sum-of-Squares Programming for Planar Robotic Arms
IEEE International Conference on Robotics and Automation (ICRA), 2024
@inproceedings{keren2024efficient,
 author = {Keren, Daniel and Shahar, Amit and Poranne, Roi},
 booktitle = {2024 IEEE International Conference on Robotics and Automation (ICRA)},
 organization = {IEEE},
 pages = {9271--9271},
 title = {Efficient Polynomial Sum-Of-Squares Programming for Planar Robotic Arms},
 year = {2024}
}
2023
-
ICRA
Interacting with Multi-Robot Systems via Mixed Reality
IEEE International Conference on Robotics and Automation (ICRA), 2023
@inproceedings{kennel2023interacting, author = {Kennel-Maushart, Florian and Poranne, Roi and Coros, Stelian}, booktitle = {2023 IEEE International Conference on Robotics and Automation (ICRA)}, organization = {IEEE}, pages = {11633--11639}, title = {Interacting with multi-robot systems via mixed reality}, year = {2023} } -
Add. Manuf.
3D Printed Spacer Fabrics
Additive Manufacturing, 2023
@article{halbrecht20233d, author = {Halbrecht, Anat and Kinsbursky, Maayan and Poranne, Roi and Sterman, Yoav}, journal = {Additive Manufacturing}, pages = {103436}, publisher = {Elsevier}, title = {3D printed spacer fabrics}, volume = {65}, year = {2023} } -
IROS
Differentiable Task Assignment and Motion Planning
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2023
@inproceedings{envall2023differentiable,
 author = {Envall, Jimmy and Poranne, Roi and Coros, Stelian},
 booktitle = {2023 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},
 organization = {IEEE},
 pages = {2049--2056},
 title = {Differentiable task assignment and motion planning},
 year = {2023}
}
2022
-
IROS
Differentiable Collision Avoidance Using Collision Primitives
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2022
@inproceedings{zimmermann2022differentiable, author = {Zimmermann, Simon and Busenhart, Matthias and Huber, Simon and Poranne, Roi and Coros, Stelian}, booktitle = {2022 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)}, organization = {IEEE}, pages = {8086--8093}, title = {Differentiable collision avoidance using collision primitives}, year = {2022} } -
RA-L
Learning Solution Manifolds for Control Problems via Energy Minimization
IEEE Robotics and Automation Letters, 2022
@article{zamora2022learning, author = {Zamora, Miguel and Poranne, Roi and Coros, Stelian}, journal = {IEEE Robotics and Automation Letters}, number = {3}, pages = {7912--7919}, publisher = {IEEE}, title = {Learning solution manifolds for control problems via energy minimization}, volume = {7}, year = {2022} } -
IROS
Obstacle Aware Sampling for Path Planning
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2022
@inproceedings{tukan2022obstacle, author = {Tukan, Murad and Maalouf, Alaa and Feldman, Dan and Poranne, Roi}, booktitle = {2022 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)}, organization = {IEEE}, pages = {13676--13683}, title = {Obstacle aware sampling for path planning}, year = {2022} } -
CAADRIA
Automatic Flythrough Authoring in VR
CAADRIA 2022 (Computer-Aided Architectural Design Research in Asia)
@inproceedings{schmidiger2022flythrough, author = {Schmidiger, Robin and Rust, Romana and Poranne, Roi}, title = {Automatic Flythrough Authoring in VR}, booktitle = {Proceedings of the 27th CAADRIA Conference}, volume = {1}, pages = {49--58}, year = {2022}, doi = {10.52842/conf.caadria.2022.1.049} } -
ICRA
Multi-arm Payload Manipulation via Mixed Reality
International Conference on Robotics and Automation (ICRA), 2022
@inproceedings{kennel2022multi, author = {Kennel-Maushart, Florian and Poranne, Roi and Coros, Stelian}, booktitle = {2022 International Conference on Robotics and Automation (ICRA)}, organization = {IEEE}, pages = {11251--11257}, title = {Multi-arm payload manipulation via mixed reality}, year = {2022} } -
SIGGRAPH Asia
Continuous Deformation Based Panelization for Design Rationalization
SIGGRAPH Asia 2022 Conference Papers
@inproceedings{jadon2022continuous, author = {Jadon, Elias and Thomaszewski, Bernhard and Apolinarska, Aleksandra Anna and Poranne, Roi}, booktitle = {SIGGRAPH Asia 2022 Conference Papers}, pages = {1--8}, title = {Continuous deformation based panelization for design rationalization}, year = {2022} } -
ACM TOG
Nonlinear Compliant Modes for Large-Deformation Analysis of Flexible Structures
ACM Transactions on Graphics, 2022
@article{duenser2022nonlinear, author = {Duenser, Simon and Thomaszewski, Bernhard and Poranne, Roi and Coros, Stelian}, journal = {ACM Transactions on Graphics}, number = {2}, pages = {1--11}, publisher = {ACM New York, NY}, title = {Nonlinear compliant modes for large-deformation analysis of flexible structures}, volume = {42}, year = {2022} } -
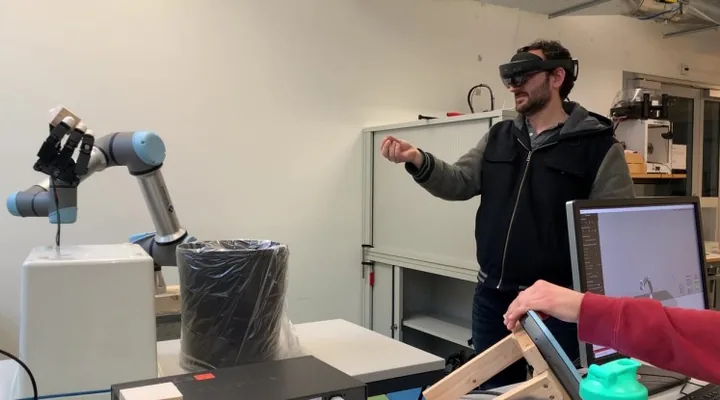
Spatial Computing and Intuitive Interaction: Bringing Mixed Reality and Robotics Together
IEEE Robotics & Automation Magazine, 2022
@ARTICLE{delmerico2022spatial,
  author={Delmerico, Jeffrey and Poranne, Roi and Bogo, Federica and Oleynikova, Helen and Vollenweider, Eric and Coros, Stelian and Nieto, Juan and Pollefeys, Marc},
  journal={IEEE Robotics & Automation Magazine},
  title={Spatial Computing and Intuitive Interaction: Bringing Mixed Reality and Robotics Together},
  year={2022},
  volume={29},
  number={1},
  pages={45-57},
  doi={10.1109/MRA.2021.3138384}}
2021
-
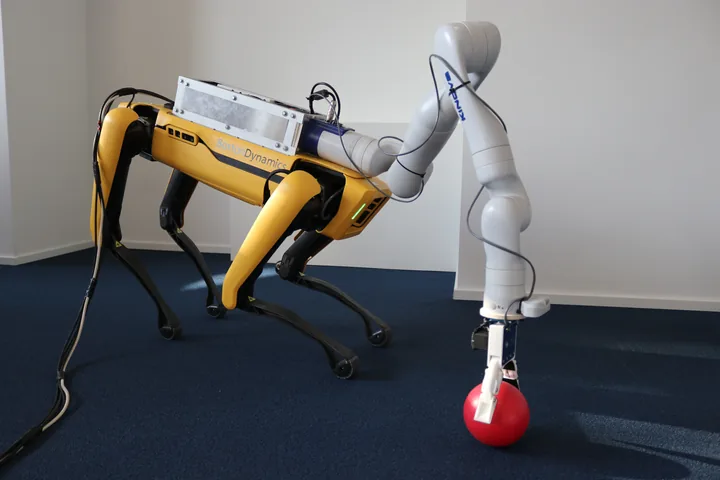
Go Fetch! - Dynamic Grasps using Boston Dynamics Spot with External Robotic Arm
IEEE International Conference on Robotics and Automation (ICRA) 2021
@inproceedings{zimmermann2021go, author = {Zimmermann, Simon and Poranne, Roi and Coros, Stelian}, booktitle = {IEEE International Conference on Robotics and Automation (ICRA) 2021}, title = {Go Fetch! - Dynamic Grasps using Boston Dynamics Spot with External Robotic Arm}, year = {2021} } -
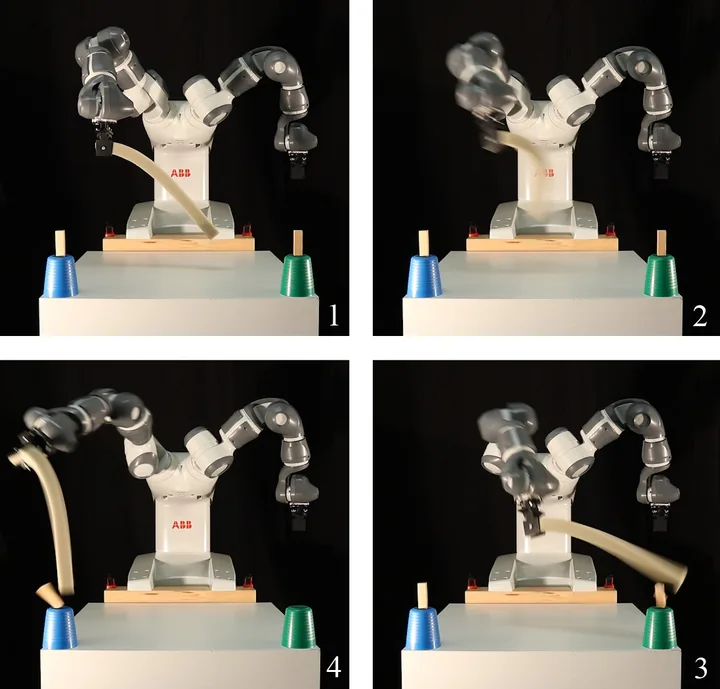
Dynamic Manipulation of Deformable Objects with Implicit Integration
IEEE Robotics and Automation Letters, 2021
@article{zimmermann2021dynamic, author = {Zimmermann, Simon and Poranne, Roi and Coros, Stelian}, journal = {IEEE Robotics and Automation Letters}, number = {2}, pages = {4209--4216}, publisher = {IEEE}, title = {Dynamic manipulation of deformable objects with implicit integration}, volume = {6}, year = {2021} } -
Task Autocorrection for Immersive Teleoperation
IEEE International Conference on Robotics and Automation (ICRA) 2021
@inproceedings{wang2021task, author = {Wang, Chenyang and Huber, Simon and Coros, Stelian and Poranne, Roi}, booktitle = {IEEE International Conference on Robotics and Automation (ICRA) 2021}, title = {Task Autocorrection for Immersive Teleoperation}, year = {2021} } -
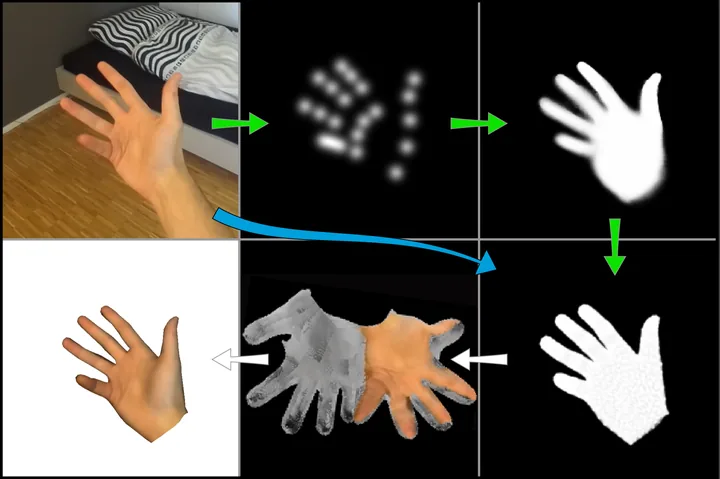
RealisticHands: A Hybrid Model for 3D Hand Reconstruction
International conference on 3D vision (3DV), 2021
@inproceedings{seeber2021realistichands, author = {Seeber, Michael and Poranne, Roi and Polleyfeys, Marc and Oswald, Martin R}, booktitle = {2021 International conference on 3D vision (3DV)}, organization = {IEEE}, pages = {22--31}, title = {Realistichands: A hybrid model for 3d hand reconstruction}, year = {2021} } -
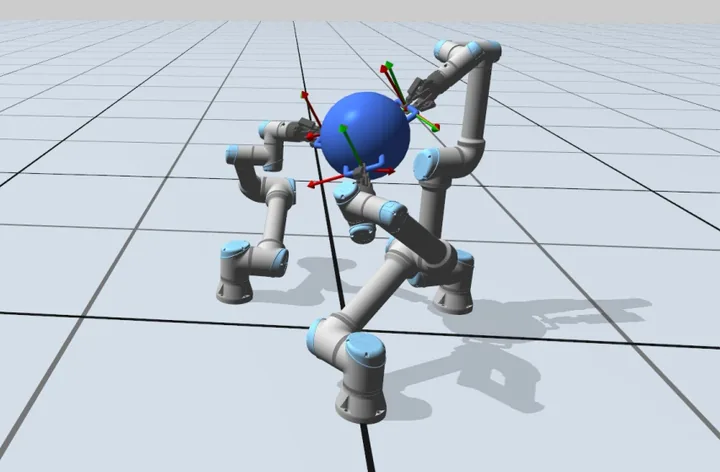
Manipulability Optimization for Multi-Arm Teleoperation
IEEE International Conference on Robotics and Automation (ICRA) 2021
@inproceedings{kennel2021manipulability, author = {Kennel-Maushart, Florian and Poranne, Roi and Coros, Stelian}, booktitle = {IEEE International Conference on Robotics and Automation (ICRA) 2021}, title = {Manipulability optimization for multi-arm teleoperation}, year = {2021} } -
Paper
Path Planning for Hyper-Redundant Surgical Robots
, 2021
@article{karnam2021path, author = {Karnam, Murali and Eugster, Manuela and Gerig, Nicolas and Poranne, Roi and Coros, Stelian and Rauter, Georg}, title = {Path Planning for Hyper-Redundant Surgical Robots}, year = {2021} } -
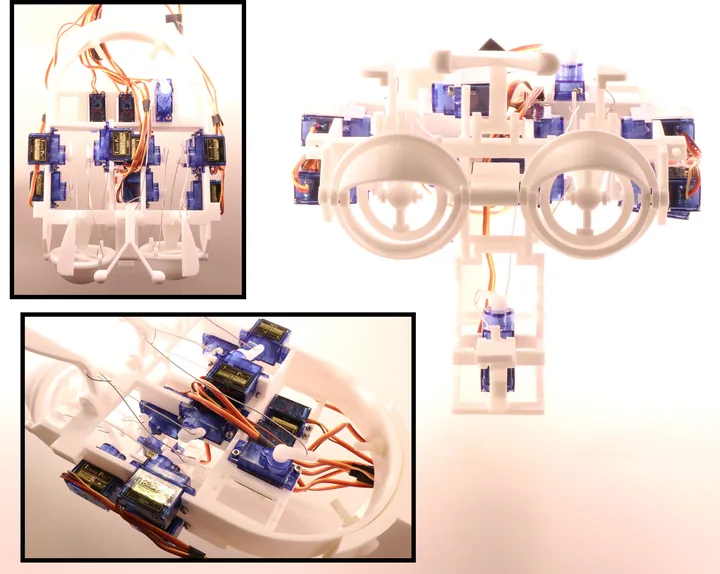
Designing Actuation Systems for Animatronic Figures via Globally Optimal Discrete Search
ACM Transactions on Graphics (SIGGRAPH 2021)
@article{huber2021designing,
 author = {Huber, Simon and Poranne, Roi and Coros, Stelian},
 journal = {ACM Transactions on Graphics (TOG)},
 number = {4},
 pages = {1--10},
 publisher = {ACM New York, NY, USA},
 title = {Designing actuation systems for animatronic figures via globally optimal discrete search},
 volume = {40},
 year = {2021}
}
2020
-
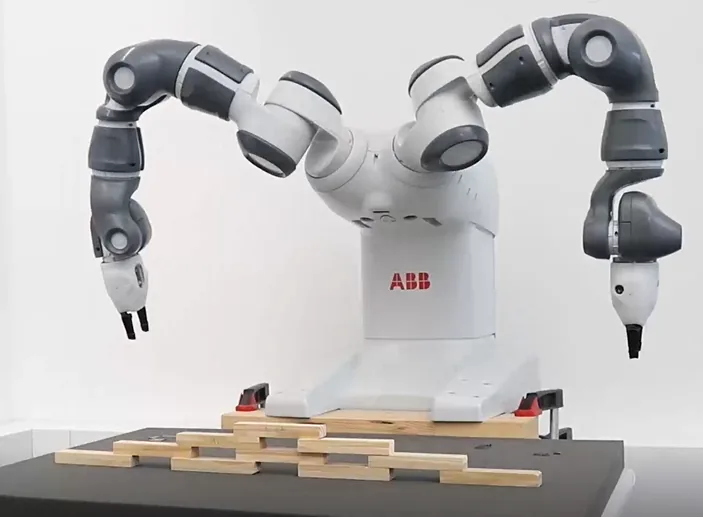
A Multi-Level Optimization Framework for Simultaneous Grasping and Motion Planning
IEEE Robotics and Automation Letters, 2020
@article{zimmermann2020multi, author = {Zimmermann, Simon and Hakimifard, Ghazal and Zamora, Miguel and Poranne, Roi and Coros, Stelian}, journal = {IEEE Robotics and Automation Letters}, number = {2}, pages = {2966--2972}, publisher = {IEEE}, title = {A multi-level optimization framework for simultaneous grasping and motion planning}, volume = {5}, year = {2020} } -
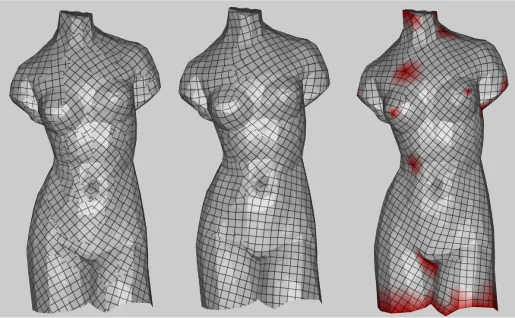
Interactive and Smooth Parametrization-Based Quadrangulation
ACM SIGGRAPH 2020 Posters
@incollection{velich2020interactive, author = {Velich, Roy and Poranne, Roi}, booktitle = {ACM SIGGRAPH 2020 Posters}, pages = {1--2}, title = {Interactive and Smooth Parametrization-Based Quadrangulation}, year = {2020} } -
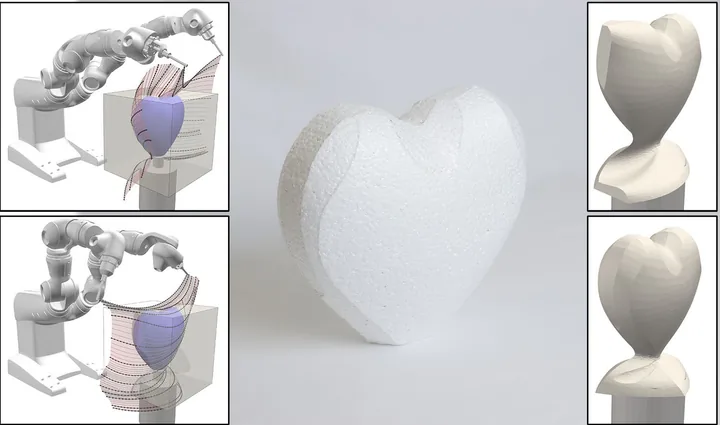
RoboCut: Hot-Wire Cutting with Robot-Controlled Flexible Rods
ACM Transactions on Graphics (SIGGRAPH 2020)
@article{duenser2020robocut,
 author = {Duenser, Simon and Poranne, Roi and Thomaszewski, Bernhard and Coros, Stelian},
 journal = {ACM Transactions on Graphics (TOG)},
 number = {4},
 pages = {98--1},
 publisher = {ACM New York, NY, USA},
 title = {RoboCut: hot-wire cutting with robot-controlled flexible rods},
 volume = {39},
 year = {2020}
}
2019
-
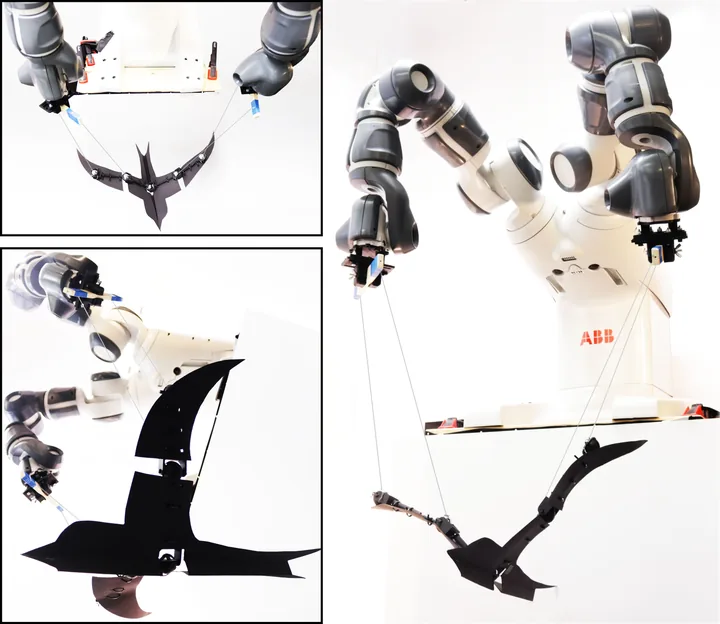
PuppetMaster: Robotic Animation of Marionettes
ACM Transactions on Graphics (SIGGRAPH 2019)
@article{zimmermann2019puppetmaster, author = {Zimmermann, Simon and Poranne, Roi and Bern, James M and Coros, Stelian}, journal = {ACM Transactions on Graphics (TOG)}, number = {4}, pages = {1--11}, publisher = {ACM New York, NY, USA}, title = {PuppetMaster: robotic animation of marionettes}, volume = {38}, year = {2019} } -
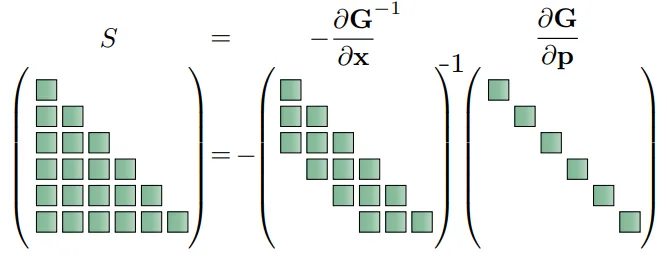
Optimal Control via Second Order Sensitivity Analysis
arXiv preprint arXiv:1905.08534, 2019
@article{zimmermann2019optimal, author = {Zimmermann, Simon and Poranne, Roi and Coros, Stelian}, journal = {arXiv preprint arXiv:1905.08534}, title = {Optimal control via second order sensitivity analysis}, year = {2019} } -
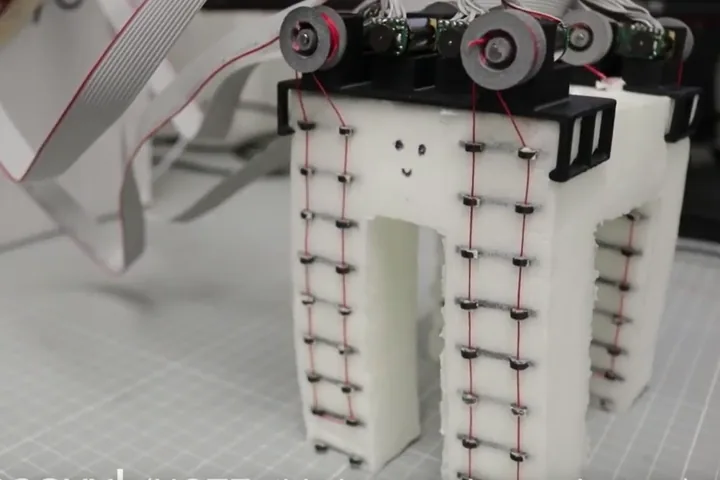
Trajectory Optimization for Cable-Driven Soft Robot Locomotion
, 2019
@article{bern2019trajectory,
 author = {Bern, James M and Banzet, Pol and Poranne, Roi and Coros, Stelian},
 title = {Trajectory optimization for cable-driven soft robot locomotion},
 year = {2019}
}
2018
-
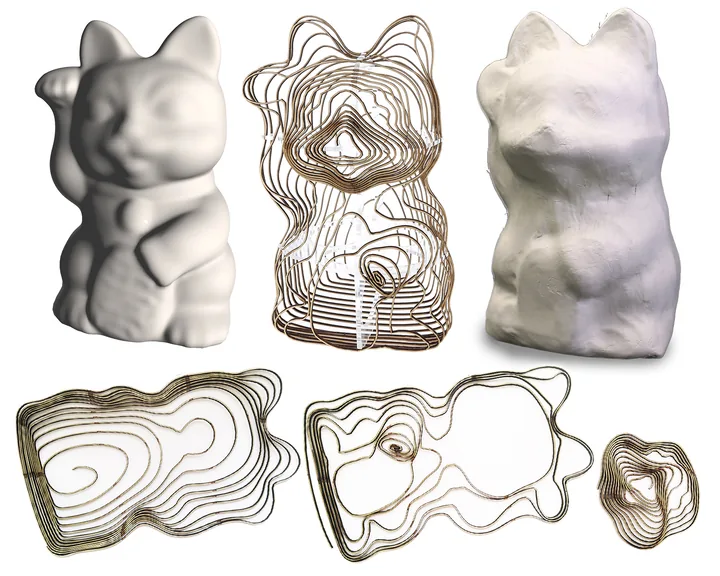
Packable Springs
Computer Graphics Forum, 2018
@inproceedings{wolff2018packable, author = {Wolff, Katja and Poranne, Roi and Glauser, Oliver and Sorkine-Hornung, Olga}, booktitle = {Computer Graphics Forum}, number = {2}, pages = {251--262}, title = {Packable springs}, volume = {37}, year = {2018} } -
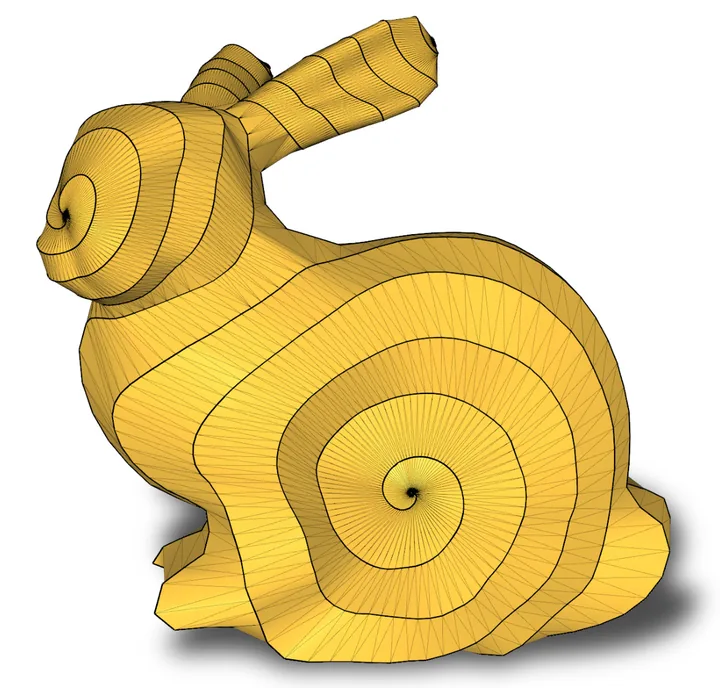
Shape Representation by Zippables
ACM Transactions on Graphics (SIGGRAPH 2018)
@article{schuller2018shape, author = {Schüller, Christian and Poranne, Roi and Sorkine-Hornung, Olga}, journal = {ACM Transactions on Graphics (TOG)}, number = {4}, pages = {1--13}, publisher = {ACM New York, NY, USA}, title = {Shape representation by zippables}, volume = {37}, year = {2018} } -
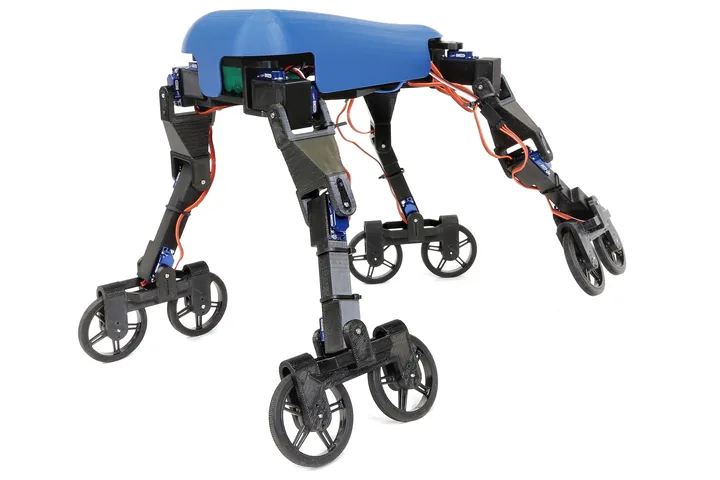
Skaterbots: Optimization-based Design and Motion Synthesis for Robotic Creatures with Legs and Wheels
ACM Transactions on Graphics (SIGGRAPH 2018)
@article{geilinger2018skaterbots, author = {Geilinger, Moritz and Poranne, Roi and Desai, Ruta and Thomaszewski, Bernhard and Coros, Stelian}, journal = {ACM Transactions on Graphics (TOG)}, number = {4}, pages = {1--12}, publisher = {ACM New York, NY, USA}, title = {Skaterbots: Optimization-based design and motion synthesis for robotic creatures with legs and wheels}, volume = {37}, year = {2018} } -
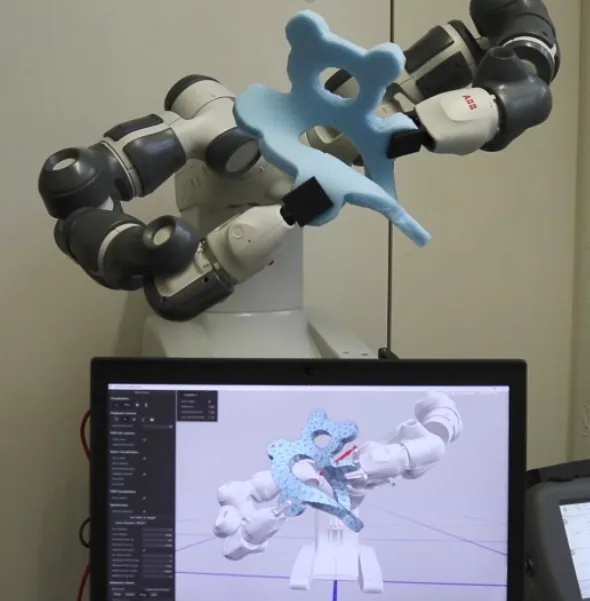
Interactive Robotic Manipulation of Elastic Objects
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2018
@inproceedings{duenser2018interactive, author = {Duenser, Simon and Bern, James M and Poranne, Roi and Coros, Stelian}, booktitle = {2018 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)}, organization = {IEEE}, pages = {3476--3481}, title = {Interactive robotic manipulation of elastic objects}, year = {2018} } -
Model-based Optimization of Tendon Layouts for Soft Robots
, 2018
@article{bern2018model,
 author = {Bern, James M and Lavarini, Luca and Poranne, Roi and Coros, Stelian},
 title = {Model-based optimization of tendon layouts for soft robots},
 year = {2018}
}
2017
-
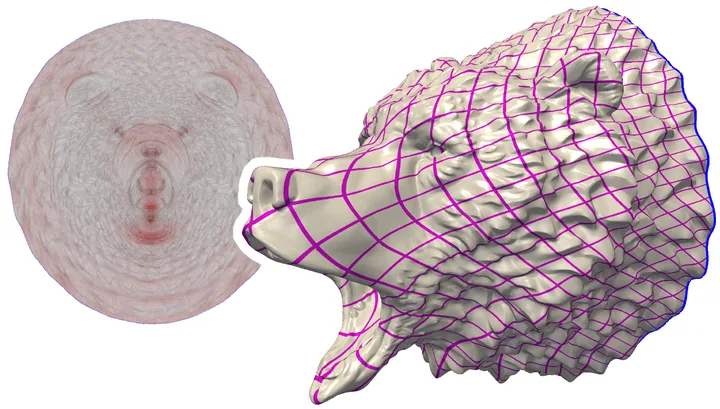
Geometric Optimization via Composite Majorization
ACM Transactions on Graphics (SIGGRAPH 2017)
@article{shtengel2017geometric, author = {Shtengel, Anna and Poranne, Roi and Sorkine-Hornung, Olga and Kovalsky, Shahar Z and Lipman, Yaron}, journal = {ACM Transactions on Graphics (TOG)}, number = {4}, pages = {1--11}, publisher = {ACM New York, NY, USA}, title = {Geometric optimization via composite majorization}, volume = {36}, year = {2017} } -
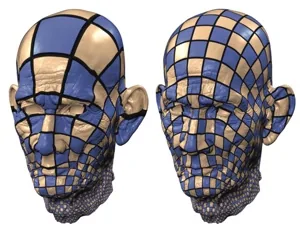
Scalable Locally Injective Mappings
ACM Transactions on Graphics (SIGGRAPH 2017)
@article{rabinovich2017scalable, author = {Rabinovich, Michael and Poranne, Roi and Panozzo, Daniele and Sorkine-Hornung, Olga}, journal = {ACM Transactions on Graphics (TOG)}, number = {4}, pages = {1}, publisher = {ACM New York, NY, USA}, title = {Scalable locally injective mappings}, volume = {36}, year = {2017} } -
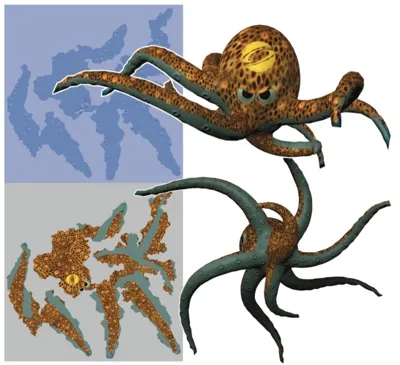
Autocuts: Simultaneous Distortion and Cut Optimization for UV Mapping
ACM Transactions on Graphics (SIGGRAPH Asia 2017)
@article{poranne2017autocuts,
 author = {Poranne, Roi and Tarini, Marco and Huber, Sandro and Panozzo, Daniele and Sorkine-Hornung, Olga},
 journal = {ACM Transactions on Graphics (TOG)},
 number = {6},
 pages = {1--11},
 publisher = {ACM New York, NY, USA},
 title = {Autocuts: simultaneous distortion and cut optimization for UV mapping},
 volume = {36},
 year = {2017}
}
2016
-
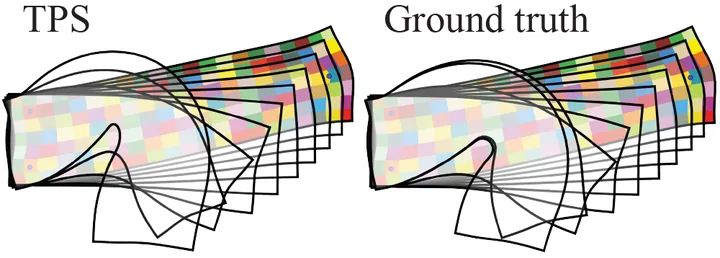
Simple Approximations of Planar Deformation Operators
Technical report, ETH Zurich, 2016
@techreport{poranne2016simple,
 author = {Poranne, Roi and Lipman, Yaron},
 institution = {ETH Zurich},
 title = {Simple approximations of planar deformation operators},
 year = {2016}
}
2015
-
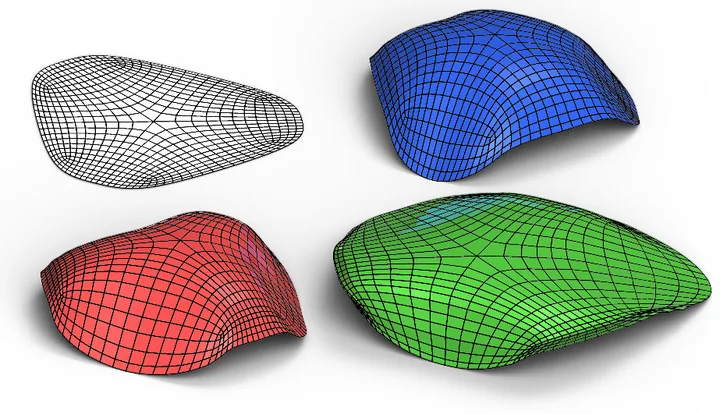
On Linear Spaces of Polyhedral Meshes
IEEE Transactions on Visualization and Computer Graphics, 2015
@article{poranne2015linear, author = {Poranne, Roi and Chen, Renjie and Gotsman, Craig}, journal = {IEEE transactions on visualization and computer graphics}, number = {5}, pages = {652--662}, publisher = {IEEE}, title = {On linear spaces of polyhedral meshes}, volume = {21}, year = {2015} } -
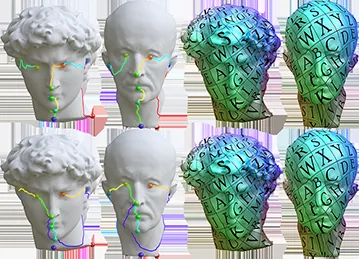
Seamless Surface Mappings
ACM Transactions on Graphics (SIGGRAPH 2015)
@article{aigerman2015seamless,
 author = {Aigerman, Noam and Poranne, Roi and Lipman, Yaron},
 journal = {ACM Transactions on Graphics (TOG)},
 number = {4},
 pages = {1--13},
 publisher = {ACM New York, NY, USA},
 title = {Seamless surface mappings},
 volume = {34},
 year = {2015}
}
2014
-
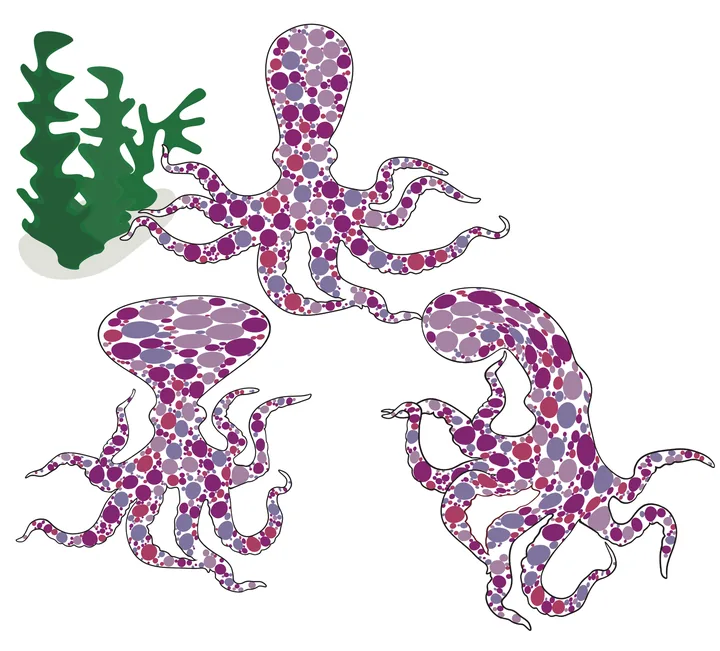
Provably Good Planar Mappings
ACM Transactions on Graphics (SIGGRAPH 2014)
@article{poranne2014provably, author = {Poranne, Roi and Lipman, Yaron}, journal = {ACM Transactions on Graphics (TOG)}, number = {4}, pages = {1--11}, publisher = {ACM New York, NY, USA}, title = {Provably good planar mappings}, volume = {33}, year = {2014} } -
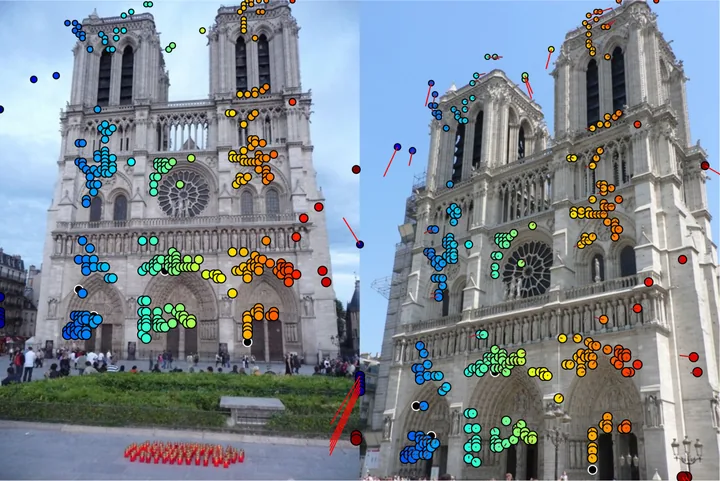
Feature Matching with Bounded Distortion
ACM Transactions on Graphics, 2014
@article{lipman2014feature, author = {Lipman, Yaron and Yagev, Stav and Poranne, Roi and Jacobs, David W and Basri, Ronen}, journal = {ACM Transactions on Graphics (TOG)}, number = {3}, pages = {1--14}, publisher = {ACM New York, NY, USA}, title = {Feature matching with bounded distortion}, volume = {33}, year = {2014} } -
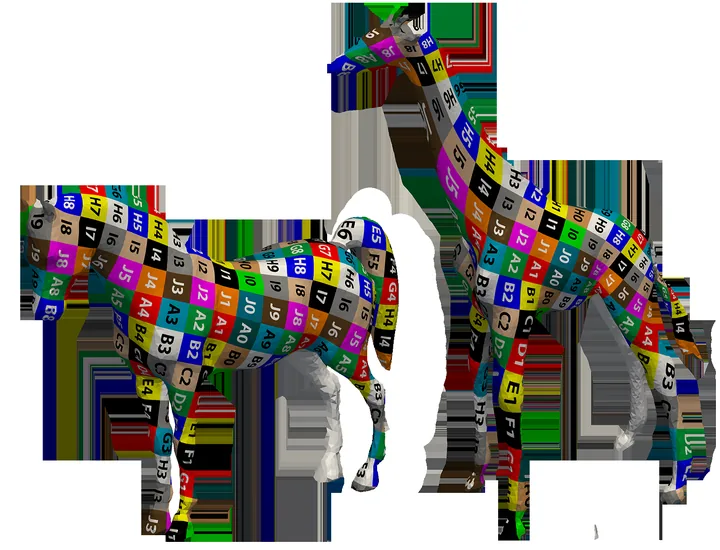
Lifted Bijections for Low Distortion Surface Mappings
ACM Transactions on Graphics (SIGGRAPH 2014)
@article{aigerman2014lifted,
 author = {Aigerman, Noam and Poranne, Roi and Lipman, Yaron},
 journal = {ACM Transactions on Graphics (TOG)},
 number = {4},
 pages = {1--12},
 publisher = {ACM New York, NY, USA},
 title = {Lifted bijections for low distortion surface mappings},
 volume = {33},
 year = {2014}
}
2013
-
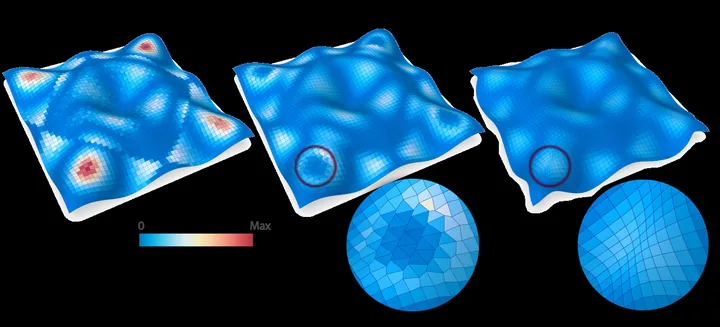
Interactive Planarization and Optimization of 3D Meshes
Computer Graphics Forum, 2013
@inproceedings{poranne2013interactive,
 author = {Poranne, Roi and Ovreiu, Elena and Gotsman, Craig},
 booktitle = {Computer Graphics Forum},
 number = {1},
 organization = {Blackwell Publishing Ltd Oxford, UK},
 pages = {152--163},
 title = {Interactive planarization and optimization of 3D meshes},
 volume = {32},
 year = {2013}
}
2012
-
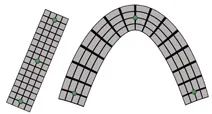
Biharmonic Coordinates
Computer Graphics Forum, 2012
@inproceedings{weber2012biharmonic,
 author = {Weber, Ofir and Poranne, Roi and Gotsman, Craig},
 booktitle = {Computer Graphics Forum},
 number = {8},
 organization = {Blackwell Publishing Ltd Oxford, UK},
 pages = {2409--2422},
 title = {Biharmonic coordinates},
 volume = {31},
 year = {2012}
}
2010
-
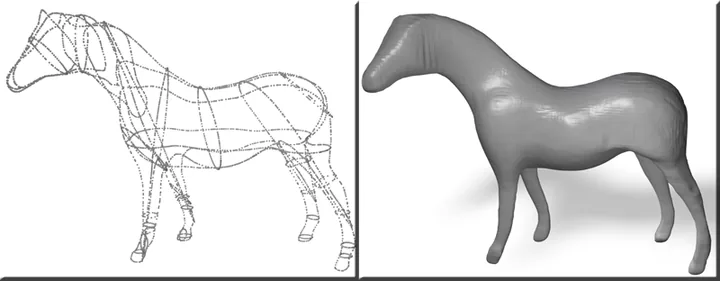
3D Surface Reconstruction Using a Generalized Distance Function
Computer Graphics Forum, 2010
@inproceedings{poranne20103d,
 author = {Poranne, Roi and Gotsman, Craig and Keren, Daniel},
 booktitle = {Computer Graphics Forum},
 number = {8},
 organization = {Blackwell Publishing Ltd Oxford, UK},
 pages = {2479--2491},
 title = {3D surface reconstruction using a generalized distance function},
 volume = {29},
 year = {2010}
}